# Android_ORB-SLAM2s
**Repository Path**: futurelei/android_-orb-slam2s
## Basic Information
- **Project Name**: Android_ORB-SLAM2s
- **Description**: 自己的编译测试版本和脚本,便于国内网络环境构建
- **Primary Language**: Unknown
- **License**: Not specified
- **Default Branch**: main
- **Homepage**: None
- **GVP Project**: No
## Statistics
- **Stars**: 0
- **Forks**: 0
- **Created**: 2026-11-01
- **Last Updated**: 2026-11-01
## Categories & Tags
**Categories**: Uncategorized
**Tags**: None
## README


[简体中文](docs/README_zh.md) · [English](README.md) · [Русский](docs/README_ru.md) · [한국어](docs/README_ko.md) · [日本語](docs/README_ja.md)
---
# 🌿 MenthaAR
**Visual SLAM solution compatible with almost all Android phones**
---
> **In a nutshell**: An enhanced spatial computing tool based on ORB-SLAM2 for Android, providing stable 6DoF spatial positioning for mobile devices.


---
## 🙏 Acknowledgments
**【Solemn Thanks】 Original ORB-SLAM2 Core:**
https://github.com/raulmur/ORB_SLAM2
**【Solemn Thanks】 Original Android ORB-SLAM2 Project:**
https://github.com/Martin20150405/SLAM_AR_Android.git
---
# 🎯 ORB-SLAM2s: Android Spatial Computing & Lightweight AR Demo
_The lowercase 's' in ORB-SLAM2s stands for **Smart · Swift · Small**, emphasizing enhanced intelligence, faster performance, and lighter weight compared to the original ORB-SLAM2._
This project uses lowercase 's'. Another paper with uppercase 'S' named ORB-SLAM2S:
```
(Y. Diao, R. Cen, F. Xue and X. Su, "ORB-SLAM2S: A Fast ORB-SLAM2 System
with Sparse Optical Flow Tracking," 2021 13th International Conference
on Advanced Computational Intelligence (ICACI), Wanzhou, China, 2021,
pp. 160-165, doi: 10.1109/ICACI52617.2021.9435915.)
```
It shares similar performance optimization concepts with this project, though its methods have not yet been integrated. This paper can serve as a valuable reference for future optimization directions. Sincere gratitude to the scholars for their contributions and sharing.
---
## 📋 Project Overview
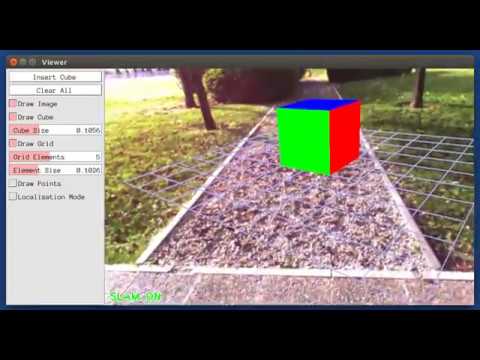
**ORB-SLAM2s** is an enhanced spatial computing tool based on ORB-SLAM2 for Android. It supports real-time sparse point cloud mapping, map saving/loading, and relocation matching. By combining computer vision, inertial navigation (IMU), and Augmented Reality (AR) technologies, this project provides stable **6DoF** (Six Degrees of Freedom) spatial positioning for mobile devices.
### 🤔 Why ORB-SLAM2 instead of ORB-SLAM3?
- **Lightweight Design**: Fewer dependencies and streamlined code, making it easier to compile and deploy on mobile platforms.
- **About IMU & VIO Support**:
- **High Barrier of ORB-SLAM3**: The VIO in the official implementation is **tightly coupled**, requiring high-quality IMU and strict **Camera-IMU timestamp synchronization**. This is common in robotics but difficult to achieve "out of the box" on Android phones via standard APIs.
- **Android Reality**: Most existing Android devices use asynchronous acquisition for Camera and IMU, lacking a unified hardware synchronization framework, and consumer-grade IMUs have significant noise/drift. Without strict calibration and synchronization, VIO is more prone to divergence than pure visual SLAM. The SENSOR_TIMESTAMP method is only available in Android 11 and later.
- **Low Resource Consumption**: Lower CPU and RAM requirements compared to ORB-SLAM3.
- **Practical Efficiency**: Performance in monocular-only scenarios is comparable to ORB-SLAM3 for standard mobile use cases.
---
## ✨ Core Features
- **🗺️ Point Cloud SLAM Mapping** —— Real-time sparse mapping based on monocular camera input
- **💾 Map Persistence** —— Save maps to local storage and reload them for future sessions
- **🎯 Relocalization & Matching** —— Pose estimation and feature matching upon loading existing maps
- **📊 Confidence Visualization** —— Visual tracking of keypoints and matching statistics between current frames and the loaded map
- **📐 Plane Detection** —— Intelligent floor/surface detection based on current pose and point cloud data
- **🎨 Native AR Rendering** —— High-performance 3D rendering via **cgltf** and OpenGL ES, supporting fast loading of GLB/glTF 3D models and interactive placement on detected planes
- **🌑 Dark Frame Detection** —— Automatically skips dark or low-quality frames to prevent SLAM thread blocking
- **🖱️ AR Object Management** —— Place, scale (pinch gesture), and interact with 3D objects
- **🧭 3DOF Orientation Tracking** —— Three-degrees-of-freedom orientation tracking using onboard device sensors (Rotation Vector / Accelerometer + Magnetometer)
- **📑 Multi-Map Support** —— Simultaneous loading and matching of multiple map files
---
## ⚡ Performance Metrics
Currently tested primarily on Qualcomm Snapdragon platform CPUs:
| SoC | Device | Performance |
| ----------------------- | --------------------- | ----------- |
| Snapdragon 8 Elite | Xiaomi 15 | 30 FPS |
| Snapdragon 8+ Gen1 | Redmi K60 | 30 FPS |
| Snapdragon 870 | Xiaomi 10S | 30 FPS |
| Snapdragon 7s Gen 2 | Redmi Pad Pro | 30 FPS |
| Snapdragon 6s Gen 2 | Redmi Pad 2 SE 4G | 30 FPS |
| Snapdragon 835 | Xiaomi 6 | 20-30 FPS |
| Snapdragon AR1 Gen 1 | Rokid Glass3 | 30 FPS |
| MediaTek Dimensity 6300 | Lenovo Xiaoxin Pad 11 | 20-30 FPS |
### 🌑 Dark Frame Detection
To ensure a smooth user experience, the system monitors exposure levels. When the environment is too dark, SLAM tracking is paused to avoid computational lag and "lost" states.
---
## ✅ Progress Tracker
- [x] Sparse Point Cloud SLAM Mapping
- [x] Map Save / Load functionality
- [x] Relocalization Matching
- [x] Basic AR Rendering Engine
- [x] Dark Frame Skip Logic
- [x] 3D AR Object Management
- [x] Simultaneous loading and matching of multiple map files
## 🗺️ Future Roadmap
- [ ] Improve mapping speed and initialization
- [ ] Enhance AR stability and 6DoF robustness
- [ ] Optimize rendering pipeline for higher frame rates
- [ ] Deepen sensor fusion (VIO —— Visual Inertial Odometry)
- [ ] SLAM frequency downsampling and adaptive noise handling
- [ ] Refined sensor gating logic
- [ ] Integration with **Unity3D**
---
## 📦 Pull Source Code
```
git clone --recursive https://github.com/Olsc/Android_ORB-SLAM2s.git
```
## 💝 Acknowledgments
This project is built upon the following excellent open-source libraries:
- [ORB-SLAM2](https://github.com/raulmur/ORB_SLAM2)
- [DBoW2](https://github.com/dorian3d/DBoW2)
- [g2o](https://github.com/RainerKuemmerle/g2o)
- [Eigen](http://eigen.tuxfamily.org/)
- [OpenCV](https://opencv.org/)
---
# 📚 ORB-SLAM2
**Authors:** [Raul Mur-Artal](http://webdiis.unizar.es/~raulmur/), [Juan D. Tardos](http://webdiis.unizar.es/~jdtardos/), [J. M. M. Montiel](http://webdiis.unizar.es/~josemari/) and [Dorian Galvez-Lopez](http://doriangalvez.com/) ([DBoW2](https://github.com/dorian3d/DBoW2))
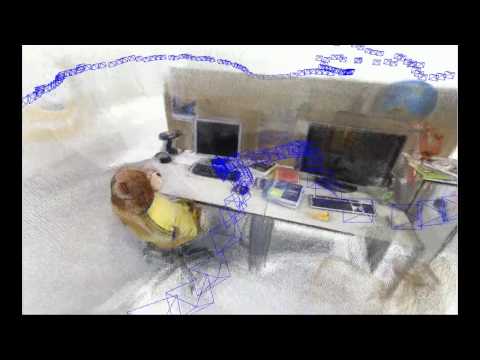
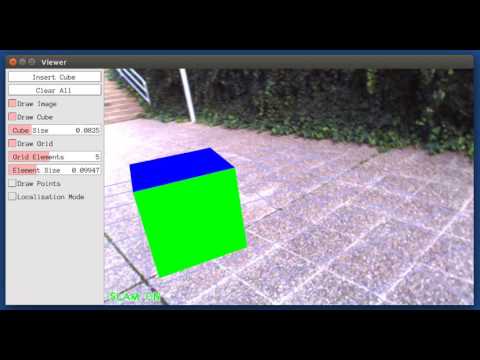
ORB-SLAM2 is a real-time SLAM library for **Monocular**, **Stereo** and **RGB-D** cameras that computes the camera trajectory and a sparse 3D reconstruction (in the stereo and RGB-D case with true scale). It is able to detect loops and relocalize the camera in real time. We provide examples to run the SLAM system in the [KITTI dataset](http://www.cvlibs.net/datasets/kitti/eval_odometry.php) as stereo or monocular, in the [TUM dataset](http://vision.in.tum.de/data/datasets/rgbd-dataset) as RGB-D or monocular, and in the [EuRoC dataset](http://projects.asl.ethz.ch/datasets/doku.php?id=kmavvisualinertialdatasets) as stereo or monocular.
 ### 📖 Related Publications
**[Monocular]** Raúl Mur-Artal, J. M. M. Montiel and Juan D. Tardós. **ORB-SLAM: A Versatile and Accurate Monocular SLAM System**. _IEEE Transactions on Robotics,_ vol. 31, no. 5, pp. 1147–1163, 2015. (**2015 IEEE Transactions on Robotics Best Paper Award**). **[PDF](http://webdiis.unizar.es/~raulmur/MurMontielTardosTRO15.pdf)**
**[Stereo and RGB-D]** Raúl Mur-Artal and Juan D. Tardós. **ORB-SLAM2: an Open-Source SLAM System for Monocular, Stereo and RGB-D Cameras**. _IEEE Transactions on Robotics,_ vol. 33, no. 5, pp. 1255–1262, 2017. **[PDF](https://128.84.21.199/pdf/1610.06475.pdf)**
**[DBoW2 Place Recognizer]** Dorian Gálvez-López and Juan D. Tardós. **Bags of Binary Words for Fast Place Recognition in Image Sequences**. _IEEE Transactions on Robotics,_ vol. 28, no. 5, pp. 1188–1197, 2012. **[PDF](http://doriangalvez.com/php/dl.php?dlp=GalvezTRO12.pdf)**
---
# 📜 License
## ORB-SLAM2 Core Library
The ORB-SLAM2 core library is released under a [GPLv3 license](https://github.com/raulmur/ORB_SLAM2/blob/master/LICENSE.txt). For a list of all code/library dependencies (and associated licenses), please see [Dependencies.md](https://github.com/raulmur/ORB_SLAM2/blob/master/Dependencies.md).
For a closed-source version of ORB-SLAM2 for commercial purposes, please contact the authors: orbslam (at) unizar (dot) es.
## This Project (ORB-SLAM2s)
This project adopts a modular license architecture based on Android IPC process isolation:
- **`app/` Module**: Licensed under the **[Apache License, Version 2.0](app/LICENSE)** (Apache-2.0). Contains UI, camera preview, native cgltf/OpenGL ES 3D rendering, and sensor components.
- **`MenthaAR/` Engine Module**: Derived from ORB-SLAM2 and released under the **[GNU General Public License v3.0](MenthaAR/LICENSE)** (GPLv3). Contains native C++ SLAM algorithms and processing.
- **Inter-Process Communication (IPC)**: The `app` module and `MenthaAR` engine run in separate Android OS processes and communicate strictly via Binder IPC and SharedMemory (Ashmem/memfd), preserving license boundaries between modules.
See [LICENSE](LICENSE), [app/LICENSE](app/LICENSE), and [MenthaAR/LICENSE](MenthaAR/LICENSE) for details.
For project collaboration or other field cooperation inquiries, please contact: **OlscStudio@outlook.com**
## Third-Party Dependencies and Licenses
This project relies on several excellent open-source third-party libraries. We strictly adhere to their respective open-source licenses:
- **[OpenCV](https://github.com/opencv/opencv)** —— **Apache 2.0 License**
- **[srrg_hbst](https://gitlab.com/srrg-software/srrg_hbst)** —— **BSD 3-Clause License**. Used for fast and scalable image matching.
- **[DBoW2](https://github.com/dorian3d/DBoW2)** —— **BSD License**. Used for basic vocabulary vectors and feature matching structures.
- **[g2o](https://github.com/RainerKuemmerle/g2o)** —— **BSD License** (core components). Used for non-linear optimization.
- **[Eigen3](http://eigen.tuxfamily.org/)** —— **MPL2 (Mozilla Public License v2.0)**. Used for matrix operations and algebraic calculations.
- **[cgltf](https://github.com/jkuhlmann/cgltf)** —— **MIT License**. Single-file C glTF 2.0 / GLB parser used for native, high-performance 3D model loading in the app module.
For any issues related to third-party licenses, please refer to their respective official repositories.
### 📝 Academic Citations
If you use ORB-SLAM2 (Monocular) in an academic work, please cite:
```bibtex
@article{murTRO2015,
title={{ORB-SLAM}: a Versatile and Accurate Monocular {SLAM} System},
author={Mur-Artal, Ra\'ul, Montiel, J. M. M. and Tard\'os, Juan D.},
journal={IEEE Transactions on Robotics},
volume={31},
number={5},
pages={1147--1163},
doi = {10.1109/TRO.2015.2463671},
year={2015}
}
```
If you use ORB-SLAM2 (Stereo or RGB-D) in an academic work, please cite:
```bibtex
@article{murORB2,
title={{ORB-SLAM2}: an Open-Source {SLAM} System for Monocular,
Stereo and {RGB-D} Cameras},
author={Mur-Artal, Ra\'ul and Tard\'os, Juan D.},
journal={IEEE Transactions on Robotics},
volume={33},
number={5},
pages={1255--1262},
doi = {10.1109/TRO.2017.2705103},
year={2017}
}
```
If you use this Android adaptation (ORB-SLAM2s) in an academic work, please acknowledge this work appropriately.
---
# ⚙️ Prerequisites
## OpenCV
We use [OpenCV](http://opencv.org) to manipulate images and features.
## HBST (Hierarchical Bag of Scalable Trees)
We have integrated [srrg_hbst](https://gitlab.com/srrg-software/srrg_hbst) for fast and scalable image matching. It significantly improves loop closing and relocalization performance compared to DBoW2.
## Eigen3
Required by g2o (see below). Download and install instructions can be found at: http://eigen.tuxfamily.org.
## DBoW2 and g2o (Included in Thirdparty folder)
We use modified versions of the [DBoW2](https://github.com/dorian3d/DBoW2) library to perform place recognition and [g2o](https://github.com/RainerKuemmerle/g2o) library to perform non-linear optimizations. Both modified libraries (which are BSD) are included in the _Thirdparty_ folder.
---
# 🧭 About Inertial Navigation (IMU)
Reference: https://github.com/Olsc/Android_3dof
_This project has not yet completed research and integration._
---
# 🧮 Theoretical Computational Complexity

---
# 🐳 Mascot

_Character: Mentha_
---
# ♥ Contributors
[](https://github.com/Olsc/Android_ORB-SLAM2s/graphs/contributors)