# solidworks_urdf_exporter3
**Repository Path**: gabr/solidworks_urdf_exporter3
## Basic Information
- **Project Name**: solidworks_urdf_exporter3
- **Description**: 原sw2robot 改进版
- **Primary Language**: Unknown
- **License**: Apache-2.0
- **Default Branch**: main
- **Homepage**: None
- **GVP Project**: No
## Statistics
- **Stars**: 0
- **Forks**: 0
- **Created**: 2026-09-13
- **Last Updated**: 2026-09-14
## Categories & Tags
**Categories**: Uncategorized
**Tags**: None
## README
# sw2robot
[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/actions/workflows/ci.yml)
[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)


[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/blob/main/LICENSE)
[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)
[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)
[](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)
> Click an OS badge to grab the latest prebuilt editor from the release page.
> Cross-platform for **edit / build / export**; the **extract** step (driving
> SolidWorks over COM) is **Windows + SolidWorks only**.
**SolidWorks → robot (URDF) converter.** Turn a SolidWorks assembly into a
URDF, then clean it up in the browser.
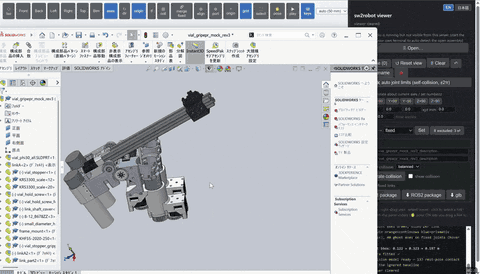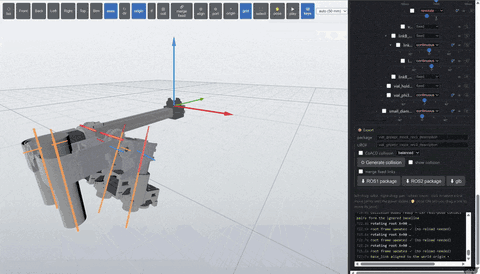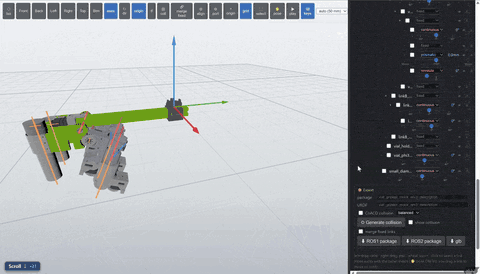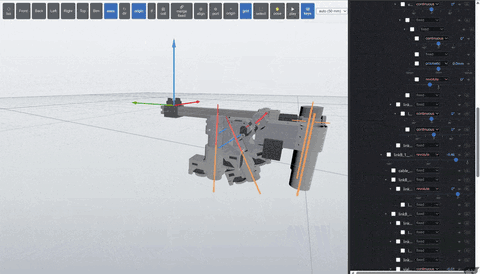
One import package, with two subpackages:
- **`sw2robot.exporter`** — the exporter. `extract` opens a throwaway copy of a `.sldasm`
in a hidden SolidWorks instance and pulls the kinematic graph + per-link
meshes into `graph.json` (slow, Windows + SolidWorks only). `build` turns that
`graph.json` into a URDF (fast, headless, no SolidWorks). The original CAD file
is never modified.
- **`sw2robot.editor`** — a single-page browser editor on top of the graph: re-root the
tree, change joint types (incl. **Shift+drag box-select** to bulk-set a range),
edit root frames, set materials/densities, see **live self-collision** as you
drag, **auto joint limits** from a self-collision sweep, and export a ROS /
robot-compiler package.
## How sw2robot relates to the classic exporter
sw2robot builds on — and is inspired by — the great, long-standing
[`solidworks_urdf_exporter`](https://github.com/ros/solidworks_urdf_exporter)
SolidWorks add-in. The two tools solve the same first mile differently, and they
**compose** rather than compete:
- **The kinematic tree is inferred, not hand-built.** The classic add-in asks you
to lay out the link hierarchy and set each joint's origin and axis by hand
inside SolidWorks. sw2robot instead **reads the assembly's existing mates
(constraints)** to infer the link tree and joint axes automatically — then lets
you correct anything it got wrong in the browser editor, rather than building it
from scratch.
- **Editing is cross-platform.** Only the *extract* step needs Windows +
SolidWorks; *edit / build / export* run natively on Windows, macOS, and Linux
from a single prebuilt binary — no SolidWorks and no Python.
- **It also edits URDFs the classic exporter produced.** Already exporting with
the classic add-in? Open that `.urdf` in sw2robot's editor to re-root the tree,
retype joints, add limits/mimic, place end-coord frames, and re-export a ROS
package. sw2robot works on *any* URDF, not only its own output.
- **An assembly the add-in already configured is read, not re-guessed.** The
add-in stores its whole configuration inside the `.SLDASM`; sw2robot finds it
and uses the authored link tree, names, frames and axes instead of inferring
them. Add `sw2urdf_config: sw2urdf_compat` to the joint config to go further and
reproduce the add-in's *own export* — its authored axis signs and the mass /
inertia it computed — so a migrated URDF matches the one you already have.
Which one fits depends on your workflow, not on which is "better":
| | classic `solidworks_urdf_exporter` | sw2robot |
| --- | --- | --- |
| Extract (assembly → URDF) | Windows + SolidWorks | Windows + SolidWorks |
| Link tree & joint axes | set by hand in SolidWorks | inferred from mates, then edited |
| Edit / build / export | inside SolidWorks (Windows) | Windows / macOS / Linux |
| Edit an existing URDF | — | ✓ (any URDF, not just its own) |
| Install | SolidWorks add-in | single prebuilt binary (no Python) |
## Install in one line (no Python, no clone)
A single command downloads the prebuilt editor for your OS, drops it on your
`PATH` as `sw2robot-web`, and you're done. No Python, no cloning this repo.
**Linux / macOS** — with `curl`:
```bash
curl -LsSf https://jsk-ros-pkg.github.io/solidworks_urdf_exporter2/install.sh | sh
```
…or with `wget` if you don't have `curl`:
```bash
wget -qO- https://jsk-ros-pkg.github.io/solidworks_urdf_exporter2/install.sh | sh
```
**Windows** — in PowerShell:
```powershell
powershell -ExecutionPolicy ByPass -c "irm https://jsk-ros-pkg.github.io/solidworks_urdf_exporter2/install.ps1 | iex"
```
Then launch the editor (it opens `http://localhost:8090` in your browser —
`xdg-open` on Linux, the default browser elsewhere):
```bash
sw2robot-web
```
The installer picks the matching `sw2robot-web--` asset from the
[latest release](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest),
installs it to `~/.local/bin` (Windows: `%LOCALAPPDATA%\sw2robot\bin`), and adds
that dir to `PATH` if needed. Knobs:
```bash
# pin a version instead of latest
SW2ROBOT_VERSION=v0.3.2 curl -LsSf https://jsk-ros-pkg.github.io/solidworks_urdf_exporter2/install.sh | sh
# or, when piping: ... | sh -s -- --version v0.3.2 --bin-dir /usr/local/bin
# choose the install dir / don't touch any shell rc
SW2ROBOT_INSTALL_DIR=/usr/local/bin SW2ROBOT_NO_MODIFY_PATH=1 curl -LsSf .../install.sh | sh
```
Prebuilt binaries currently ship for **Linux x64**, **Linux arm64**,
**macOS (Apple Silicon)**, and **Windows x64**. Re-running the installer upgrades
in place; the editor can
also self-update from its own UI. Prefer to grab the file by hand, or need a
different OS/arch? The per-OS steps below still apply.
### Opening a `.urdf` with sw2robot
The installer also registers a `.urdf` file association, so you can hand a URDF
straight to the editor the same way on Linux and macOS:
```bash
xdg-open robot.urdf # Linux
open robot.urdf # macOS
```
Either launches the editor with that URDF loaded (URDF-input mode). A `.urdf`
also gets an **Open With → sw2robot** entry in the file manager / Finder, and
sw2robot shows up in your application menu. Pass `SW2ROBOT_NO_DESKTOP=1` to the
installer (or `--no-desktop`) to skip this. Linux needs `xdg-utils` installed
for the association; without it the binary still installs and the step is
skipped with a note.
## Quick start — download the Windows `.exe` (no Python)
If you just want to convert a SolidWorks assembly, you don't need to install
Python or clone this repo. Grab the prebuilt editor and run it:
1. **Download.** Go to the
[latest release](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)
and download `sw2robot-web-windows-x64-v.exe` (under *Assets*).
It's a single self-contained file — nothing to install.
2. **Run it.** Double-click the `.exe`. A console window opens, a local server
starts, and your default browser opens the editor at
`http://localhost:8090` automatically.
- Windows SmartScreen may warn that the publisher is unknown (the binary is
unsigned). Click **More info → Run anyway**.
- To pick a different port or skip auto-opening the browser, run it from a
terminal: `sw2robot-web-windows-x64-v.exe --port 9000 --no-browser`.
3. **Extract a robot.** Open your `.sldasm` assembly with the in-app file
picker — the **🗄 file browser** (lists SolidWorks' recent files for
one-click access) or **📋 paste a full path**. SolidWorks needs the real
on-disk path to resolve referenced parts, which a browser never exposes for
a drag-and-dropped file, so the editor opens by path rather than by drop.
The app drives a hidden SolidWorks instance to pull the kinematic graph +
meshes. Your original CAD file is never modified. Extracted packages are
written to `%TEMP%\sw2robot\output`.
- **The extract step needs SolidWorks installed on the same machine** — the
app talks to it over COM; it does not embed SolidWorks.
- No SolidWorks? You can still open and edit an already-extracted package,
and the build / export steps work without it.
4. **Clean it up.** In the editor: re-root the tree, set joint types
(Shift+drag to bulk-set a range), edit the root frame, set materials and
densities, watch live self-collision as you drag joints, and run the
auto joint-limit sweep.
5. **Export.** Export a ROS / robot-compiler package (URDF + meshes + configs)
from the editor, ready to drop into your workspace.
Closing the console window stops the server and tears down the SolidWorks
instance it spawned.
## Quick start — macOS / Linux (no SolidWorks)
SolidWorks does not run on macOS / Linux, so the `extract` step (assembly →
graph) is Windows-only. **Everything else — open & edit an already-extracted
package, open & edit *any* URDF, build, and export — runs natively** on macOS
and Linux.
**Option A — download the prebuilt editor** (no Python). Grab the asset for
your OS from the [latest release](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/releases/latest)
(under *Assets*):
**macOS (Apple Silicon)** — `sw2robot-web-macos-arm64-v.zip`. Unzip it
to get `sw2robot-web.app`; double-click to launch (it opens the editor in your
browser at `http://localhost:8090`).
```bash
# Gatekeeper blocks unsigned apps on first launch — clear the quarantine once,
# then double-click, or run it from a terminal to see the server log / URL:
xattr -dr com.apple.quarantine sw2robot-web.app
./sw2robot-web.app/Contents/MacOS/sw2robot-web
```
**Linux (x64)** — `sw2robot-web-linux-x64-v` (a single binary):
```bash
chmod +x sw2robot-web-linux-x64-v # mark it executable once
./sw2robot-web-linux-x64-v # opens http://localhost:8090
```
The binary is frozen against GLIBC 2.35, so it runs on **Ubuntu 22.04 or newer**
(22.04, 24.04, …). On older distros you may hit a `GLIBC_2.xx not found` error
at launch — in that case run from source (Option B below) instead.
**Option B — run from source** (see [Install from source](#install-from-source-developers)
below):
```bash
pip install -e ".[ui]"
# edit an already-extracted package, or open any URDF directly:
python -m sw2robot.editor.webserver path/to/robot.urdf
```
The editor opens in URDF-input mode when you point it at a `.urdf` file: re-root,
retype joints, set mimic/limits/materials, add end-coord ports, and re-export a
ROS package — then closing the tab leaves your original `.urdf` untouched.
## Editor — features & keyboard shortcuts
Everything below edits the package server-side and rebuilds the URDF in place
(~0.5 s), so the viewer always shows the real exported result.
**Kinematics**
- **Make root** — pick any link and make it the base; the tree is re-rooted and
every edge between the old and new root is flipped automatically.
- **Joint types** — toggle a joint fixed ↔ movable, or **Shift+drag** a box over
the tree to bulk-set a whole range at once.
- **Flip axis** — reverse a joint's positive direction in one keystroke.
- **Mimic** — link follower joints to a master so they move together; set a
**multiplier** and **offset** per follower (URDF ``). Move the master
and the followers track it live.
- **Delete subtree** — drop a link and everything below it.
- **Actuator & physics** — per movable joint, set `` effort/velocity and
the optional URDF `` (damping/friction), ``
(soft limits, k_position, k_velocity) and `` (rising/falling).
Blank fields stay unset. Persisted in `joints.yaml`, so they survive a
re-extract (or hand-edit the same keys under each joint in `joints.yaml`).
**Coordinate frames**
- **Root frame** — rotate the root about its current axes or type exact numbers;
or click a face to **align the root** to it (origin = face center). Written as
`root_rpy` / `root_xyz` in `joints.yaml`.
- **⊕ Port (end-coords)** — click a face to drop a named, coordinate-only link
there with **+Z = the face normal**, then nudge it with the gizmo
(`g` move / `r` rotate) and **Place**. Handy for end-effector, sensor, or
mount frames. Click a magenta marker to remove one. Stored under `ports:` in
`joints.yaml`.
- **Export shape + weight?** — the checkbox on each link row in the joint tree.
Uncheck it for a CAD-only part (a `dummy_axis` drawn just to carry a joint
axis): the link and its joint stay in the tree, but the URDF gets a bare
frame — no ``, no ``, no ``. Stored as
`frame_only:` in `joints.yaml`. (Different from **mass-only**, which keeps the
weight and only works on a fixed child.)
- **CAD coordinate systems** — every named SolidWorks coordinate system (in the
assembly, a sub-assembly, or inside a part file) becomes one of these
coordinate-only links automatically, on the part it was drawn in — or, for a
frame drawn in the top-level assembly, on the component its origin was picked
from. Turn it off or pick a subset with `coordinate_system_links: off | all |
[, ...]` in `joints.yaml`; the default skips frames an embedded SW2URDF
config already uses as link origins.
**Authoring aids** — live self-collision highlight as you drag a joint, an
**auto joint-limit** sweep, per-link materials/densities, a `tf` view (frame
triads + parent links), and a sizeable ground grid.
**Navigation** — left-drag orbits, right-drag pans, the wheel dollies right into
the assembly so you can inspect internal parts. **Double-click a link** to make
it the orbit centre (then orbit and zoom around that part); press **`v`** to
recentre the orbit on it, or **`c`** for a full view reset.
**Keyboard shortcuts** (with a link selected or hovered):
| Key | Action |
| --- | --- |
| `t` | toggle joint **fixed ↔ movable** |
| `f` | **flip** the joint axis / direction |
| `m` | start **mimic** linking (then click followers · `Enter`/`m` apply · `Esc` cancel) |
| `r` / `R` | **make root** at this link |
| `Del` / `Backspace` | delete the link **+ its subtree** |
| `0` / `Home` | reset **pose** (all joints to 0) |
| `c` | reset the **view** (pose, iso camera, orbit back on the model) |
| `v` | **recentre** the orbit on the focused link (or model), keeping your angle/zoom |
| `Esc` | clear selection / cancel the current mode |
| `click` · `dbl-click` · `Shift+drag` | select · **focus** (orbit around it + jump to its tree row) · box-select a range |
| mouse | left-drag orbit · right-drag pan · wheel zoom (dollies right inside the model) |
In a port/end-coords placement session the gizmo owns the keys: `g` move,
`r` rotate, `Esc` cancel.
## Install from source (developers)
Prefer this if you want to hack on sw2robot or run it on a non-Windows machine
(view / edit / build / export work anywhere; only *extract* needs Windows +
SolidWorks).
```bash
pip install -e . # core: extract / build / web editor (view+edit)
pip install -e ".[ui]" # + live collision highlight, auto joint-limits
```
`[ui]` adds `python-fcl` (collision queries); `scikit-robot` (FK, primitive
fitting) is a core dependency. The editor's view / edit / extract / build work
without `[ui]`; collision and auto-limits just report "not available" until it
is installed.
## Use
**Extract a `.sldasm` -> URDF** (Windows, with SolidWorks installed):
```bash
python -m sw2robot.exporter.export path/to/assembly.sldasm -o output
```
**Or a single `.sldprt` -> URDF.** Point the exact same command (or the editor's
🗄 file browser / 📋 path bar) at a lone part instead of an assembly:
```bash
python -m sw2robot.exporter.export path/to/part.sldprt -o output
```
A single part has no mates to infer a kinematic tree from, so this yields a
trivial **1-link, 0-joint URDF** — one rigid body with the part's mesh and its
**SolidWorks-native mass / centre-of-mass / inertia tensor** (exact CAD geometry
+ material, not a mesh estimate). Handy for a static prop, an environment
object, or a single end-effector/sensor body you want in a simulator with an
accurate inertial. It will not turn a multibody part into a jointed robot — that
needs an assembly with mates.
**Open the browser editor** on an already-extracted package (no SolidWorks
needed — a sample is included):
```bash
python -m sw2robot.editor.webserver examples/fingertip
# then open http://localhost:8090
```
From the editor you can also extract a fresh package: open a `.sldasm` with the
in-app file picker (🗄 file browser of SolidWorks' recent files, or 📋 paste a
full path) and it drives SolidWorks for you. It opens by real on-disk path —
not by browser drag-and-drop, which never exposes the path SolidWorks needs to
resolve referenced parts.
**Headless build / edit / export** (no GUI):
```bash
python -m sw2robot.editor # see the CLI
```
**Export a MuJoCo model.** `--mujoco` writes a standalone `_mjcf`
package — an MJCF model plus its binary-STL assets — next to the URDF one, and
the editor has the same thing as a **⬇ MuJoCo (MJCF)** button:
```bash
# straight from the assembly
python -m sw2robot.exporter.export path/to/assembly.sldasm -o output --mujoco
# or from an already-extracted package (no SolidWorks)
python -m sw2robot.exporter.build output/ --mujoco
```
A URDF that loads in RViz is not yet a model you can train on, so the export
does more than change file format. It merges fixed links (MuJoCo has no use for
one body per screw), then derives from the CAD itself:
* **per-joint damping** of `effort / velocity` — the torque-speed slope of that
joint's own servo, so a leg cannot be swung faster in sim than the real motor
can drive it;
* **a contact sphere per foot**, sized from that foot's own contact patch and
tangent to its lowest point, because the convex hull of a flat bracket end
gives contact points that jump around under a walking policy;
* **an IMU site and the sensors a locomotion task looks up by name**
(`imu_ang_vel`, `imu_lin_vel`, `imu_lin_acc`, `root_angmom`);
* **a `home` keyframe** whose base height is computed so nothing starts below
the floor.
The base floats by default. `--mujoco-fixed-base` welds it to the world for an
arm bolted to a table — which also drops the foot spheres and the IMU, both
legged-robot features. `--mujoco-armature` takes the reflected rotor inertia,
the one number a CAD model cannot supply (it depends on the motor and the gear
ratio), and defaults to 0. `--collision` applies here as it does to the ROS
package.
Feeding it to an RL framework that brings its own actuator model (mjlab, say,
which deletes the MJCF's actuators and keyframe and substitutes its own) needs
two things: `--mujoco-no-backemf-damping`, so the joint is not damped twice, and
foot names that match what the task config selects on. The contact sphere and
site are named after the link (`FL_foot_toe`, `FL_foot`) unless you say
otherwise; `write_mjcf_package(foot_links={"FL_foot": "FL", ...})` names them
after the leg instead (`FL_toe`, `FL`), which is the usual locomotion-task
convention.
The MJCF itself is written by
[`skrobot.urdf.urdf_to_mjcf`](https://github.com/iory/scikit-robot), which is
also where the per-joint damping and the measured base height come from. Real
CAD meshes routinely include shapes MuJoCo's compiler refuses — a material-split
single triangle, a stamped part with zero enclosed volume, a perfectly flat
sheet — so this needs **scikit-robot 0.3.34 or newer**; on 0.3.33 such an
assembly fails with `mesh volume is too small` or `at least 4 vertices
required`.
**Fast re-extract while debugging.** Keep the assembly open in SolidWorks, then:
```bash
# reuse the running SolidWorks (skips the multi-minute reopen)
python -m sw2robot.exporter.extract path/to/assembly.sldasm --attach
# refresh ONLY coordinate systems / reference axes in graph.json (seconds)
python -m sw2robot.exporter.extract output/ --refresh frames --attach
```
## Layout
```
sw2robot/ one import package (pip install sw2robot)
exporter/ SolidWorks -> graph.json -> URDF
editor/ the browser editor (server + single-page web/index.html)
_vendor/rc_config/ vendored ROS/MoveIt/Gazebo config generators
examples/fingertip/ a small pre-extracted package to try the editor offline
tests/ pytest (sw2robot.exporter classification) + tests/e2e (puppeteer UI suite)
```
## Tests
```bash
PYTHONPATH= pytest # sw2robot.exporter unit tests
cd tests/e2e && npm i && node run.mjs # UI suite (needs a running sw2robot-web + Chrome)
```
Some pytest fixtures expect a cached `output//graph.json`; those skip when
absent.
## Contributing
Please read [CONTRIBUTING.md](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/blob/main/CONTRIBUTING.md) before opening an issue or pull
request. In short: discuss first via an issue, keep PRs small and focused,
attach a demo video for UI changes, and disclose any AI usage.
## License
[Apache License 2.0](https://github.com/jsk-ros-pkg/solidworks_urdf_exporter2/blob/main/LICENSE) © 2026 Iori Yanokura