# hexapod **Repository Path**: gausshuang/hexapod ## Basic Information - **Project Name**: hexapod - **Description**: 又找到一个纯前端实现的开源项目!mithi写的hexapod模拟器直接在浏览器运行,不依赖任何框架。 通过Pure JavaScript实现了六足机器人各种运动学问题的计算,同时用Plotly.js做了个简洁大方的可视化界面。 项目代码结构清晰,算法实现 efficiently,让人深深地被这种利用原生JS做大事的开发思路所感染。 这个项目也提供了库的形式可以引入其他项目,对学习JavaSc - **Primary Language**: JavaScript - **License**: Apache-2.0 - **Default Branch**: master - **Homepage**: None - **GVP Project**: No ## Statistics - **Stars**: 1 - **Forks**: 0 - **Created**: 2023-11-03 - **Last Updated**: 2024-04-19 ## Categories & Tags **Categories**: Uncategorized **Tags**: None ## README [![build status](https://github.com/mithi/hexapod/workflows/build/badge.svg)](https://hexapod.netlify.app) [![Code Climate](https://codeclimate.com/github/mithi/hexapod/badges/gpa.svg)](https://codeclimate.com/github/mithi/hexapod) [![technical debt](https://img.shields.io/codeclimate/tech-debt/mithi/hexapod)](https://codeclimate.com/github/mithi/hexapod/trends/technical_debt) [![codecov](https://codecov.io/gh/mithi/hexapod/branch/master/graph/badge.svg)](https://codecov.io/gh/mithi/hexapod) [![code style: prettier](https://img.shields.io/badge/code_style-prettier-ff69b4.svg?style=flat)](https://github.com/prettier/prettier) [![buy me coffee](https://img.shields.io/badge/Buy%20me%20-coffee!-orange.svg?logo=buy-me-a-coffee&color=795548)](https://ko-fi.com/minimithi) # Mithi's Bare-Minimum Hexapod Robot Simulator 2

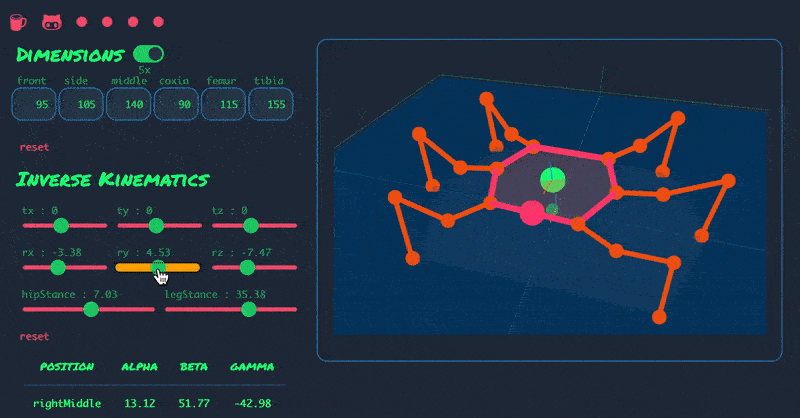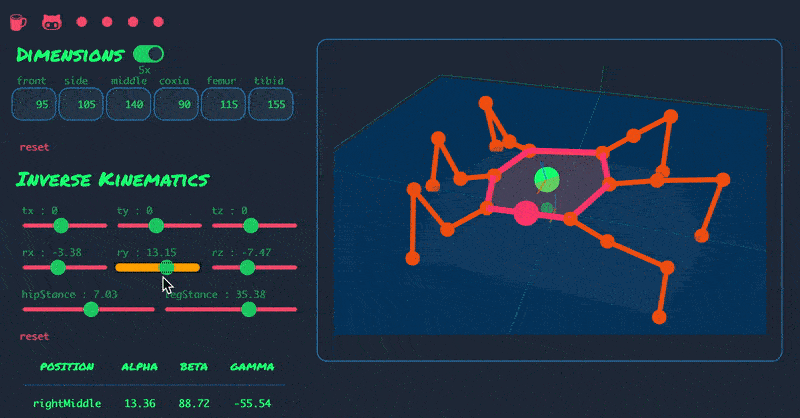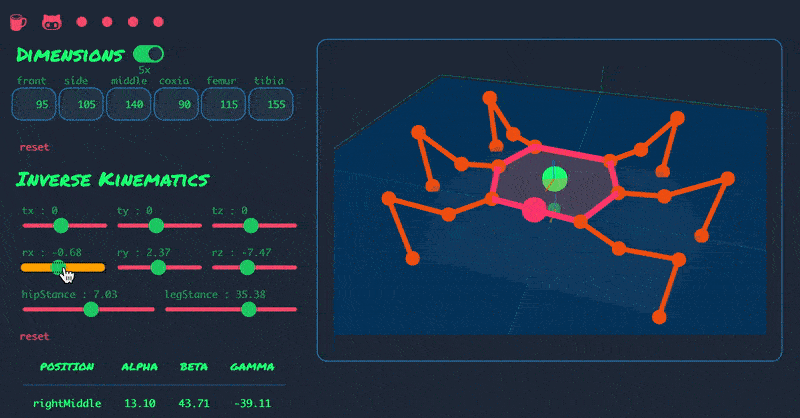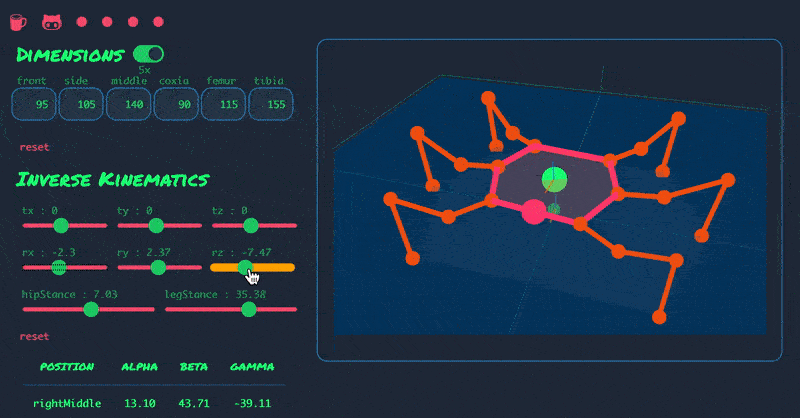
drawing

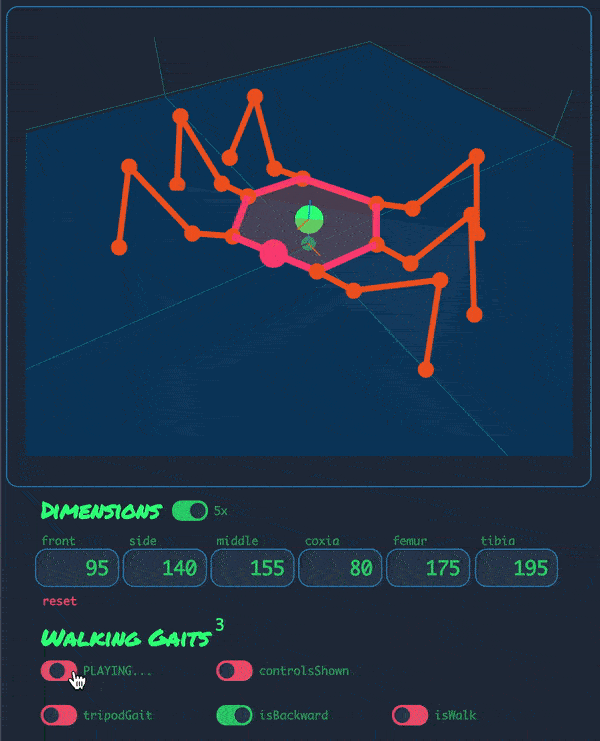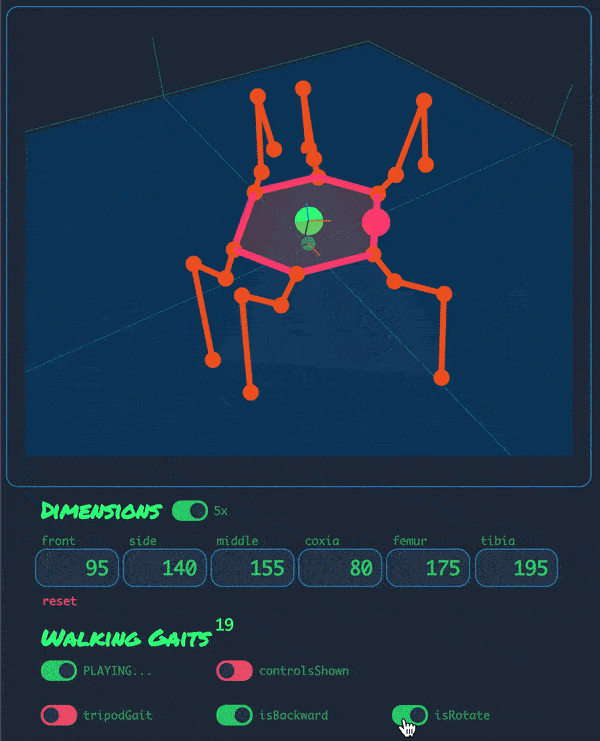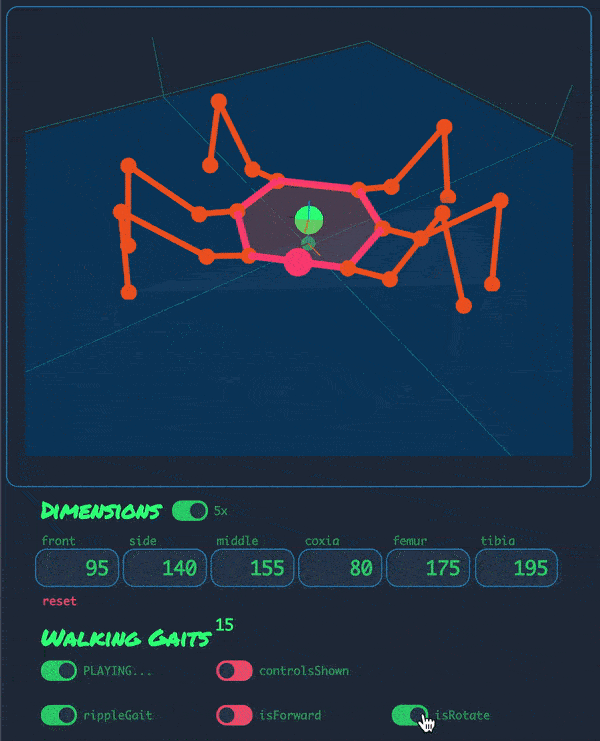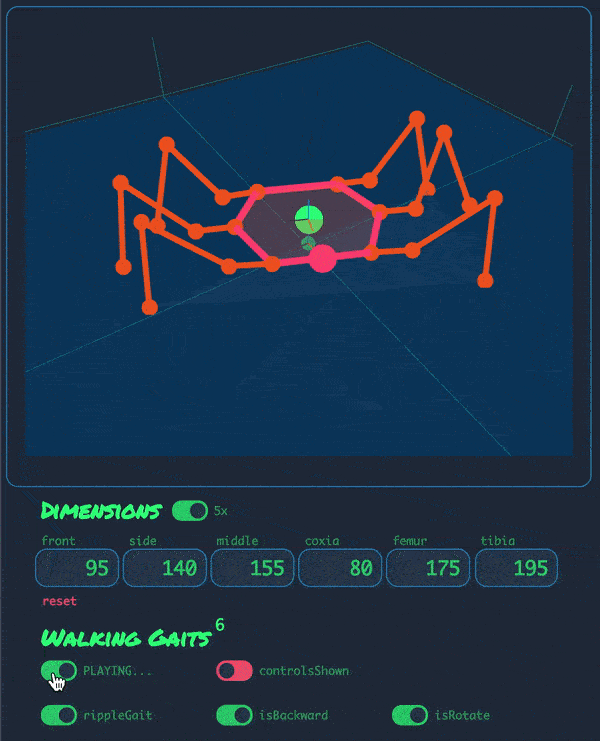
You can use this web app to solve inverse kinematics, simulate various gaits, and more. In real time, you can also view all the angles the robot's eighteen joints make at any particular pose. All the computations are solely done in your browser, nothing's fetching data from somewhere else, so it should be fast. Another (somewhat) cool thing is that this app does NOT depend on any external mathematics library; it only uses Javascript's built-in Math object. Consider buying me [a few cups of coffee ☕ ☕ ☕](https://ko-fi.com/minimithi) to motivate me to build other robotics-related visualizers. (Quadrotors?!) ## Features drawing 🎉 Control - [x] The robot's dimensions - [x] The robot's 3d orientation, translation, stance, and more 🎉 Solve - [x] Inverse Kinematics - [x] Forward Kinematics 🎉 Simulate - [x] Ripple and tripod gait variations - [x] Walking forward and backwards - [x] Rotating clockwise and counterclockwise [🤖](https://hexapod.netlify.app/) [🐳](https://mithi.github.io/deep-blueberry/) [☕](https://ko-fi.com/minimithi) ## Related Things If you'd like to build your own user interface with Node, you can download the algorithm alone as a package: [Hexapod Kinematics Library](https://github.com/mithi/hexapod-kinematics-library). There is also [a "fork" modified where you can use the app to control a physical hexapod robot](https://github.com/mithi/hexapod-irl) as you can see in the gif below. |![](https://user-images.githubusercontent.com/1670421/103467849-46981980-4d8e-11eb-911e-7cb63282c0c2.gif)|![](https://user-images.githubusercontent.com/1670421/103467765-451a2180-4d8d-11eb-8f94-1a23201595b9.gif)| |--------|-------| | Walking Gaits | Kinematics | ## Main Contributors [![PRs welcome!](https://img.shields.io/badge/PRs-welcome-orange.svg?style=flat)](./CONTRIBUTING.md) Any contribution to improve the source code is always appreciated. [See contributing Guide](./CONTRIBUTING.md). I will put your name below if I've merged your PR multiple times or if you've substantially contributed to this project in other ways. - [@mithi](https://github.com/mithi) - [@icyJoseph](https://github.com/icyJoseph) - [@mikong](https://github.com/mikong) ## I love badges! (Don't we all?) [![License](https://img.shields.io/badge/License-Apache%202.0-orange.svg?style=flat)](https://opensource.org/licenses/Apache-2.0) [![code climate issues](https://img.shields.io/codeclimate/issues/mithi/hexapod?label=code%20climate%20issues)](https://codeclimate.com/github/mithi/hexapod/issues) [![last commit](https://img.shields.io/github/last-commit/mithi/hexapod)](https://github.com/mithi/hexapod/commits/master) [![commits per month](https://img.shields.io/github/commit-activity/m/mithi/hexapod?color=yellow&style=flat)](https://github.com/mithi/hexapod/graphs/commit-activity) ![top language](https://img.shields.io/github/languages/top/mithi/hexapod) ![code files size](https://img.shields.io/github/languages/code-size/mithi/hexapod?color=yellow) ![repo size](https://img.shields.io/github/repo-size/mithi/hexapod?color=violet) [![code base blanks count](https://tokei.rs/b1/github/mithi/hexapod?category=blanks)](https://github.com/mithi/hexapod) [![code base line count](https://tokei.rs/b1/github/mithi/hexapod?category=lines)](https://github.com/mithi/hexapod) [![number of files count](https://tokei.rs/b1/github/mithi/hexapod?category=files)](https://github.com/mithi/hexapod) [![number of comments line in code base](https://tokei.rs/b1/github/mithi/hexapod?category=comments)](https://github.com/mithi/hexapod) [![lines of code](https://tokei.rs/b1/github/mithi/hexapod?category=code)](https://github.com/mithi/hexapod) [![HitCount](http://hits.dwyl.com/mithi/hexapod.svg)](http://hits.dwyl.com/mithi/hexapod)